Isabel de Luis
Researcher. Engineer. Explorer.
About Me:
I’m a second-year graduate student at MIT AeroAstro, conducting research with Prof. Julie Shah’s Interactive Robotics Group and Dr. Ben Armstrong at the Industrial Performance Center. I received my Bachelor of Science in Engineering from Olin College of Engineering in May 2025. My research focuses on human-computer interaction, human–AI collaboration, and the development of safe, transparent, and trustworthy intelligent systems. I’m also the founder of OASIS (Ocean Analytics for Species Identification and Surveillance), a conservation technology initiative that uses AI and crowdsourced underwater imagery to monitor marine biodiversity and track invasive species. Through OASIS, I’m exploring how human expertise and intelligent systems can work together to support marine conservation. Previously, I’ve conducted research at Caltech, MIT, and NASA’s Jet Propulsion Laboratory, investigating human factors and autonomy in aviation and space exploration.
Human Factors in Control Rooms
My human factors research focuses on how people interact with intelligent and increasingly autonomous systems, particularly in complex, safety-critical environments. Working with Prof. Julie Shah and Dr. Ben Armstrong at MIT, I investigate how situation awareness, trust in automation, cognitive workload, and team coordination influence human performance and decision-making. My current research examines human–automation collaboration in integrated remote operations centers for the mining industry, where operators must supervise interconnected processes, interpret automated recommendations, and coordinate decisions under uncertainty. More broadly, I am interested in designing intelligent systems that complement human expertise, support informed decision-making, and maintain meaningful human oversight as automation becomes increasingly capable.
OASIS is an AI-powered marine conservation initiative I founded to transform recreational underwater photography into valuable biodiversity monitoring data. Every year, millions of divers and tourists photograph marine ecosystems, often unknowingly capturing species and ecological changes in the backgrounds of their images. While these photographs contain a wealth of potentially useful scientific information, most never reach researchers. OASIS aims to bridge this gap by transforming everyday underwater imagery into a scalable, accessible source of biodiversity observations, with a particular focus on monitoring the spread of invasive marine species.
There are so many words I could use to describe OASIS, but I think the most apt description is that OASIS is my baby. I developed it from the ground up, I pursued opportunities to pilot it, and I applied to countless funding opportunities. Nothing I have ever built has made me prouder, or more excited than this.
I began developing OASIS after visiting the Galápagos Islands in 2025, where I was struck by the number of tourists photographing marine life and began wondering whether their images could contribute to conservation research. In the summer of 2026, I partnered with the Charles Darwin Foundation to develop and pilot OASIS in the Galápagos Marine Reserve. This work was funded by MIT’s Priscilla King Grey Fellowship. I built a machine learning pipeline capable of identifying multiple species within underwater photographs, incorporating ecological context and uncertainty-based triage to prioritize images requiring expert review. By combining automated image analysis with human expertise, OASIS seeks to make biodiversity monitoring more efficient without sacrificing scientific reliability.
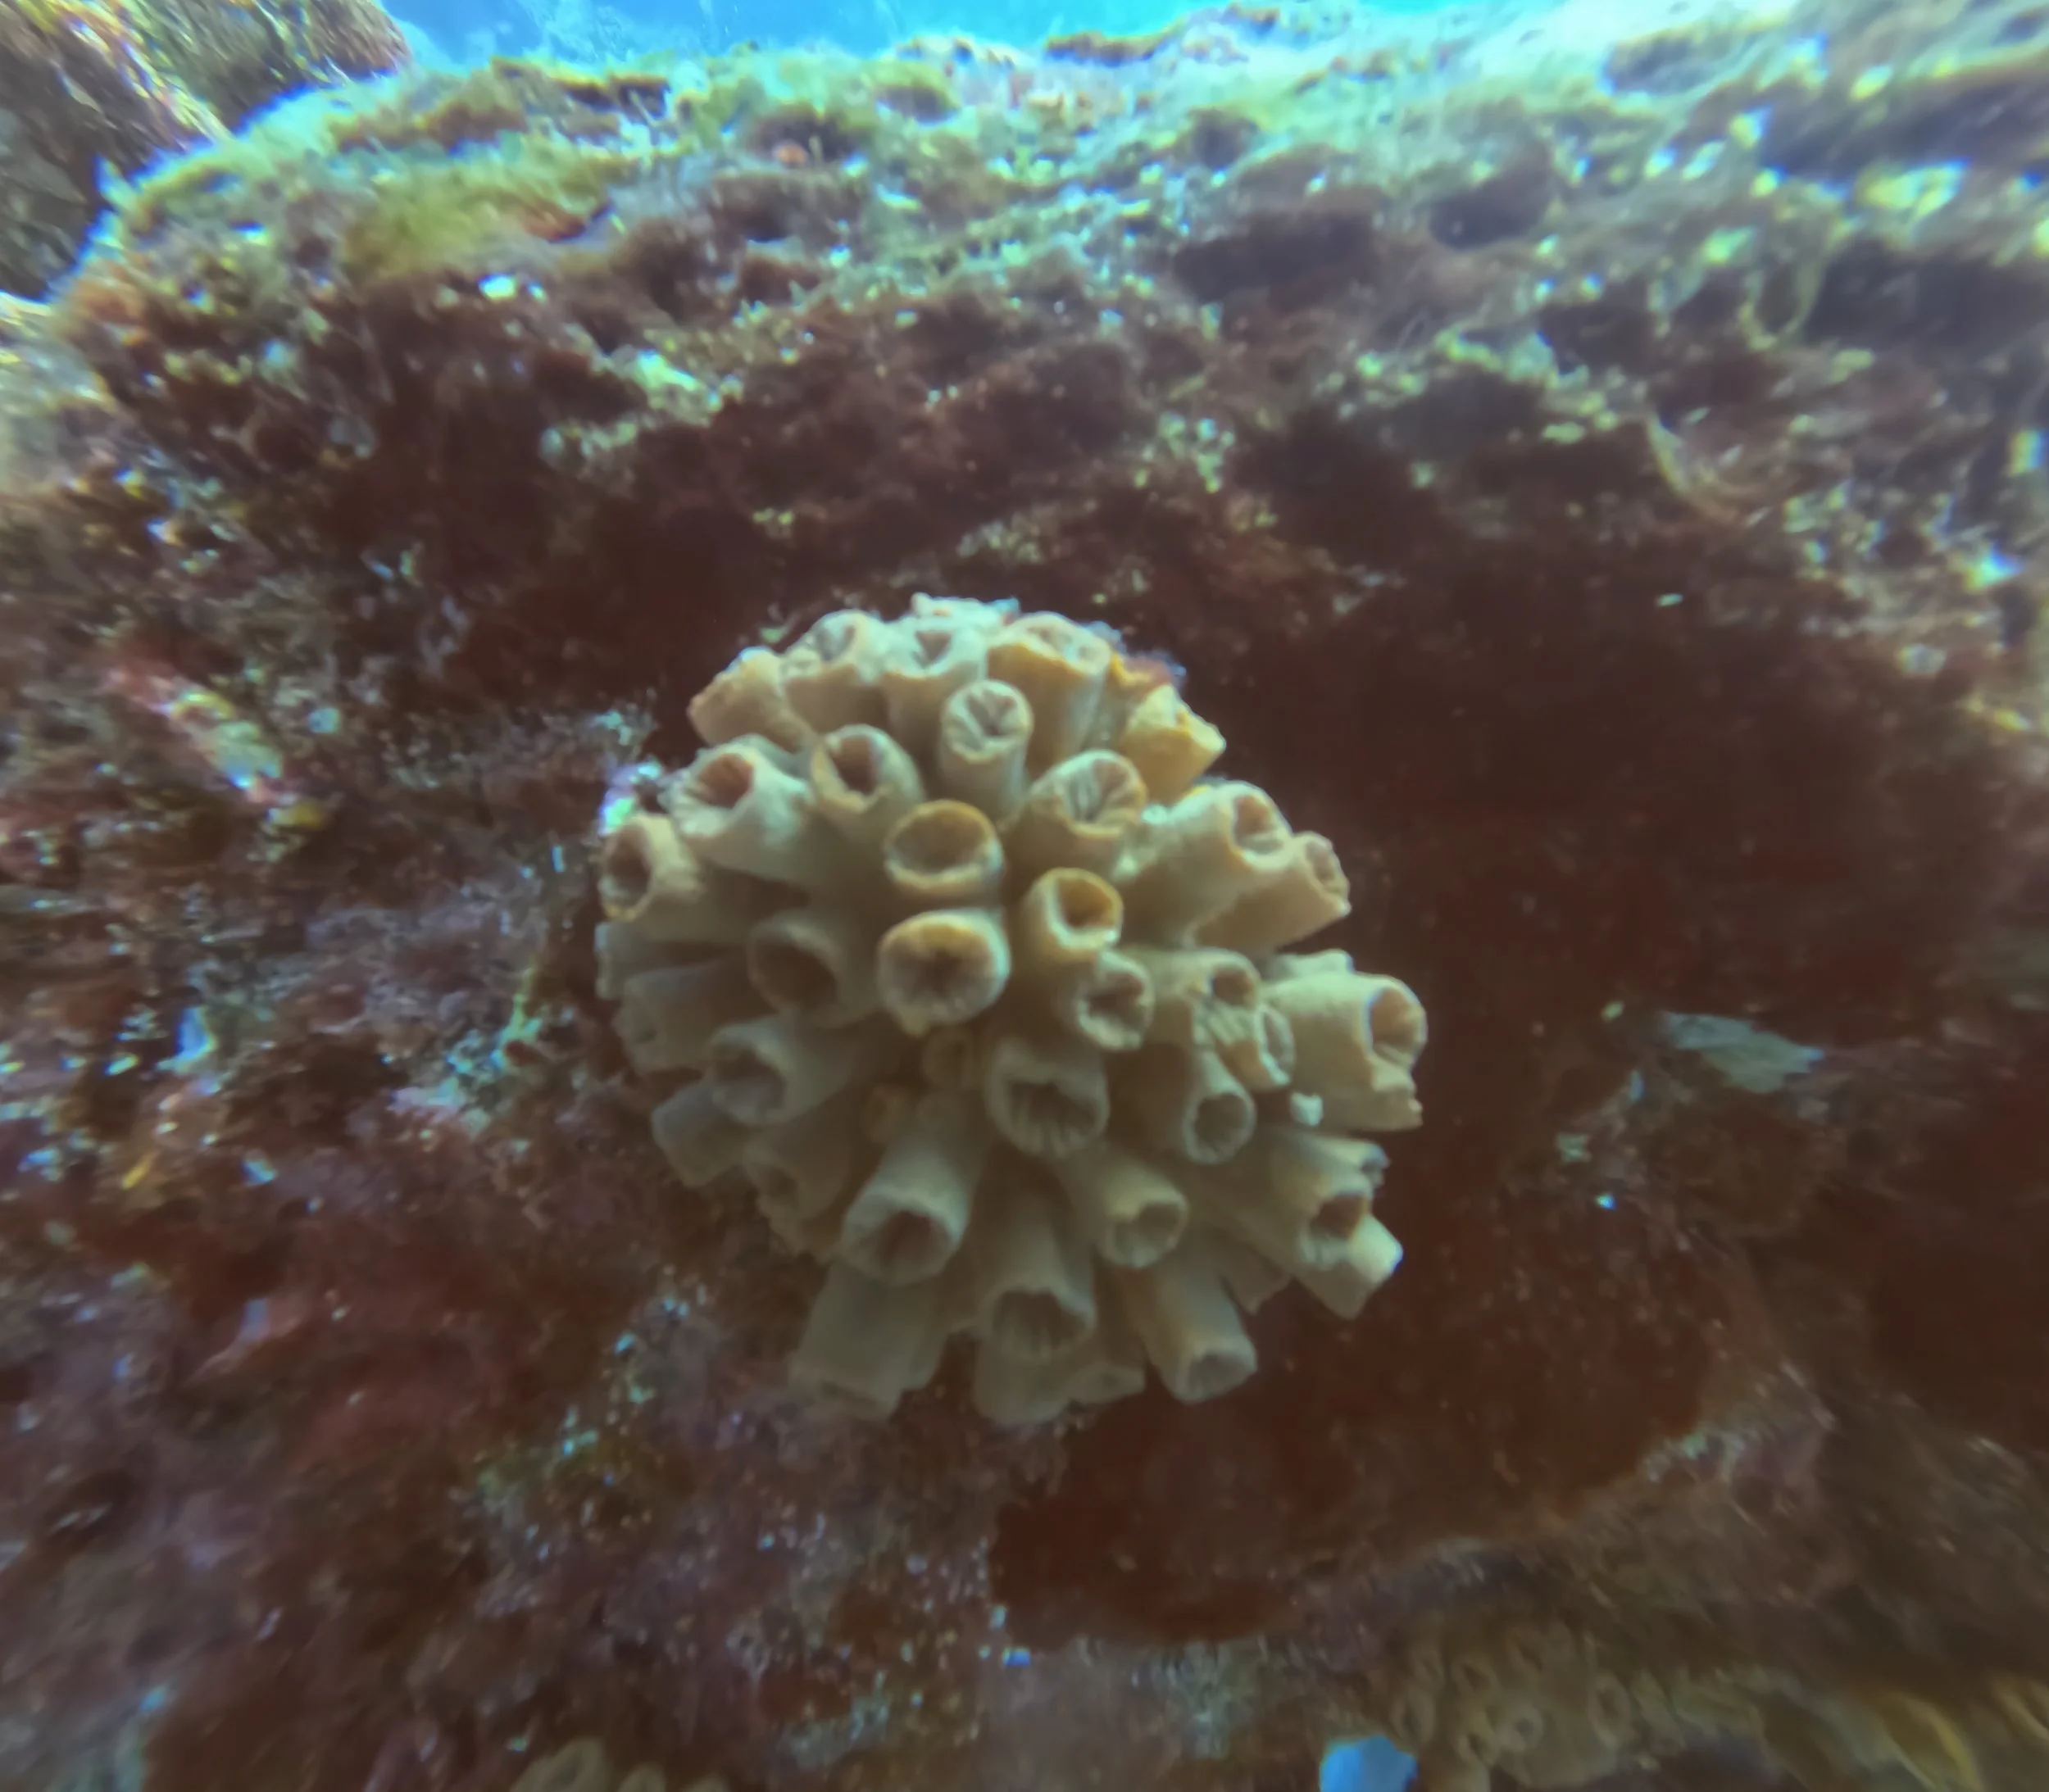
Unlike traditional citizen science initiatives that often require participants to identify species or follow standardized observation protocols, OASIS is designed around passive participation. Divers and snorkelers can contribute the photographs they already take, even if the subject of the image is not scientifically interesting. In fact, the background of an ordinary vacation photo may contain the most valuable observation. This approach has the potential to expand the geographic and temporal coverage of marine biodiversity monitoring by engaging people who might never otherwise participate in scientific research.
Building on the initial Galápagos pilot, I am expanding OASIS to the Caribbean through partnerships in Honduras, with the goal of evaluating how well the approach generalizes across different marine ecosystems and understanding what motivates tourists to contribute their imagery. My longer-term vision is to establish a global network of citizen-contributed underwater observations that helps scientists detect emerging invasions, monitor biodiversity changes, and make better-informed conservation decisions.
OASIS also serves as a foundation for my broader research interests in human–AI collaboration and autonomous ocean exploration. I am particularly interested in how intelligent systems can incorporate scientific expertise, communicate uncertainty, and identify observations worth investigating further. Ultimately, I envision connecting OASIS with autonomous underwater robots to enable adaptive biodiversity surveys guided by human scientists.
Through OASIS, I hope to make marine conservation more accessible, participatory, and data-driven, demonstrating how artificial intelligence and collective human curiosity can work together to better understand and protect our oceans.
Highlighted Projects
R-Based NMF Pipeline for Air Quality Data
Spring 2025, Air Partners, Olin College of Engineering
I developed a pipeline document in R Studio to perform Non-Negative Matrix Factorization (NMF) on cleaned air quality data from Air Partner’s air quality sensors around Boston. The pipeline included documentation on how the NMF analysis was performed and included the ability to automatically create spatial maps of pollutants around the sensor based on the results of the NMF analysis.
Aircraft Accident Predictor
Fall 2024, Olin College of Engineering
I built a Multi-Layer Perceptron (MLP) model to predict the primary cause of aviation accidents, aiming to give investigators an initial analytical starting point. Using NTSB accident data, I cleaned, encoded, and balanced the dataset with class weighting and SMOTE. The model reached about 50% accuracy with stable training and test performance, demonstrating both the potential and challenges of applying machine learning to real-world aviation data.
Air Quality Analysis in Galena Park
Fall 2024, Air Partners, Olin College of Engineering
Galena Park, a community near the Port of Houston, faces poor air quality from surrounding industrial activity. The Environmental Community Advocates of Galena Park (ECAGP) partnered with Air Partners, a team of Olin College students, to analyze data from their air quality sensor network. I developed a data-cleaning pipeline and analyzed over six months of sensor data, finding that PM2.5 concentrations consistently ranged between 12–29 µg/m³, well above the EPA’s 9 µg/m³ exposure limit, and peaked during daytime industrial operations.
Simulating Low-Cost Landers on Mars
Summer 2024, NASA’s Jet Propulsion Laboratory
To support NASA’s low-cost Mars mission program, I developed a Python-based simulation tool to model and optimize Mars lander subsystem parameters such as drag coefficient and nose cone angle. I also built a user-friendly GUI for early mission design use. Validated against past JPL lander data, the tool accurately reproduced expected landing outcomes in all test cases.
Lion Air 610 CAST Analysis
Summer 2023, MIT
I performed a Causal Analysis using Systems Theory (CAST) on the Lion Air 610 Crash to support the research Prof. Nancy Leveson’s Cybersecurity and System Safety Lab was doing. I found 11 contributions to the crash, from improper regulations to faulty equipment and prepared a paper that discussed how human factors investigations in aviation accidents often have narrow views of human error and focus on assigning blame for accidents instead of viewing human error in the context which it occurred.
Neural Fly
Summer 2022, Caltech
I supported Caltech’s Neural Fly project by developing a bridge between the drone simulator in Python and the hardware in C++ so that the simulator controller could be used on the hardware. For this I used ROS, Python, and C++, and I tested my wrapper using a software-in-the-loop (SITL) simulator before verifying my code with 3 field tests with the drone hardware.